Pick and Place Robot
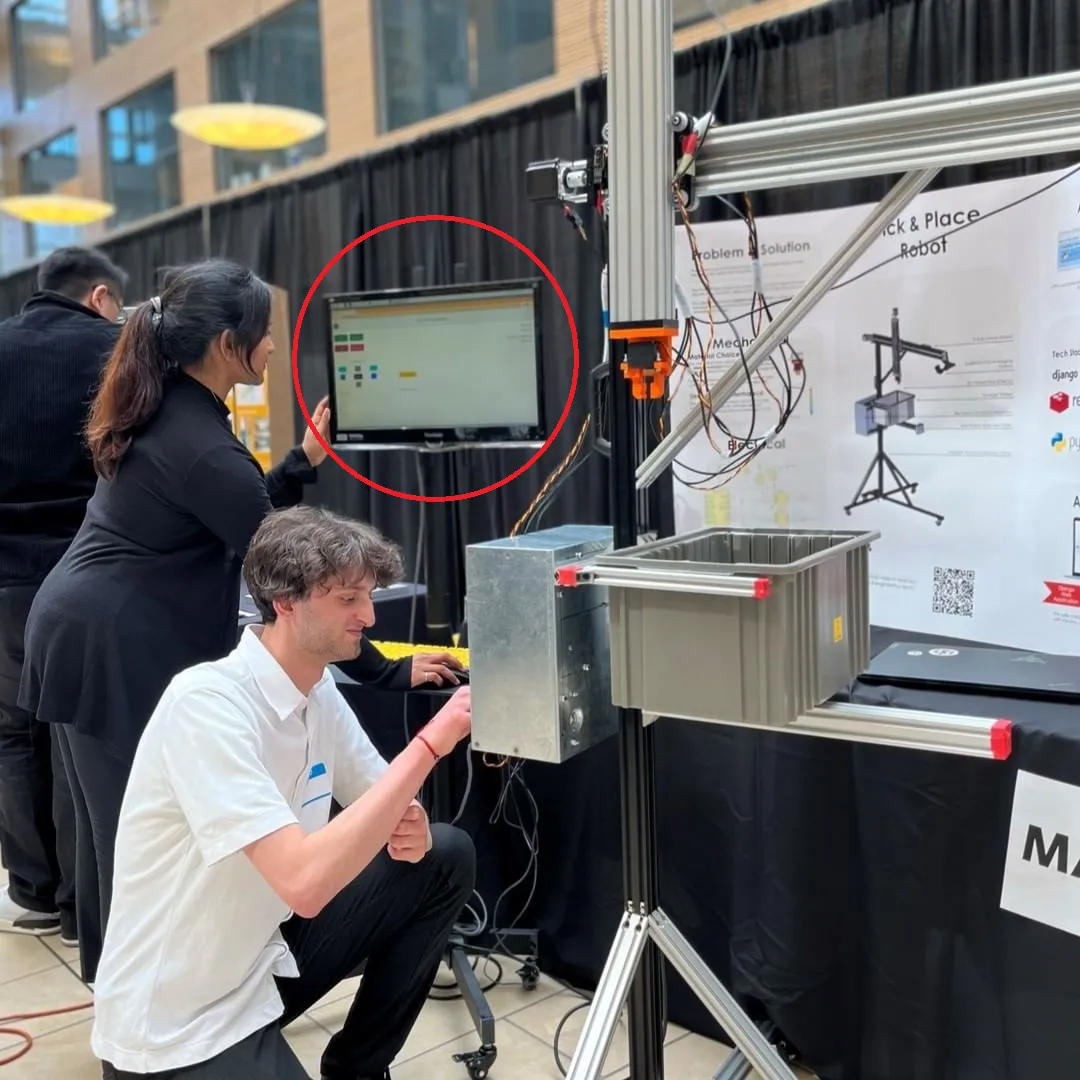
Our capstone team of 5 created a Pick and Place robot to fully automate the plastic manufacturing process in the university laboratory. The lab had an IMM (Injection Molding Machine), which had to be manually loaded and unloaded.
We aimed to automate the loading, unloading, Q/A, and storage using a 2-axis robot with a gripper and storage box. My role was to build a HMI, to connect the user to the robot. Hosted on a Pi, my website was connected to the robot and the IMM through UBC's network.
The website was used to wirelessly control the robot in semi-auto and manual modes. In auto mode, it provided diagnostic and progress info. Since the robot hosted the website, any device can authenticate into the website to control the robot or monitor cycle statistics.